
AI-Powered 3D Delta Robot for Pick & Place
- Client
- Factory automation & robotics
- Year
- 2025
- Category
- Industrial Automation
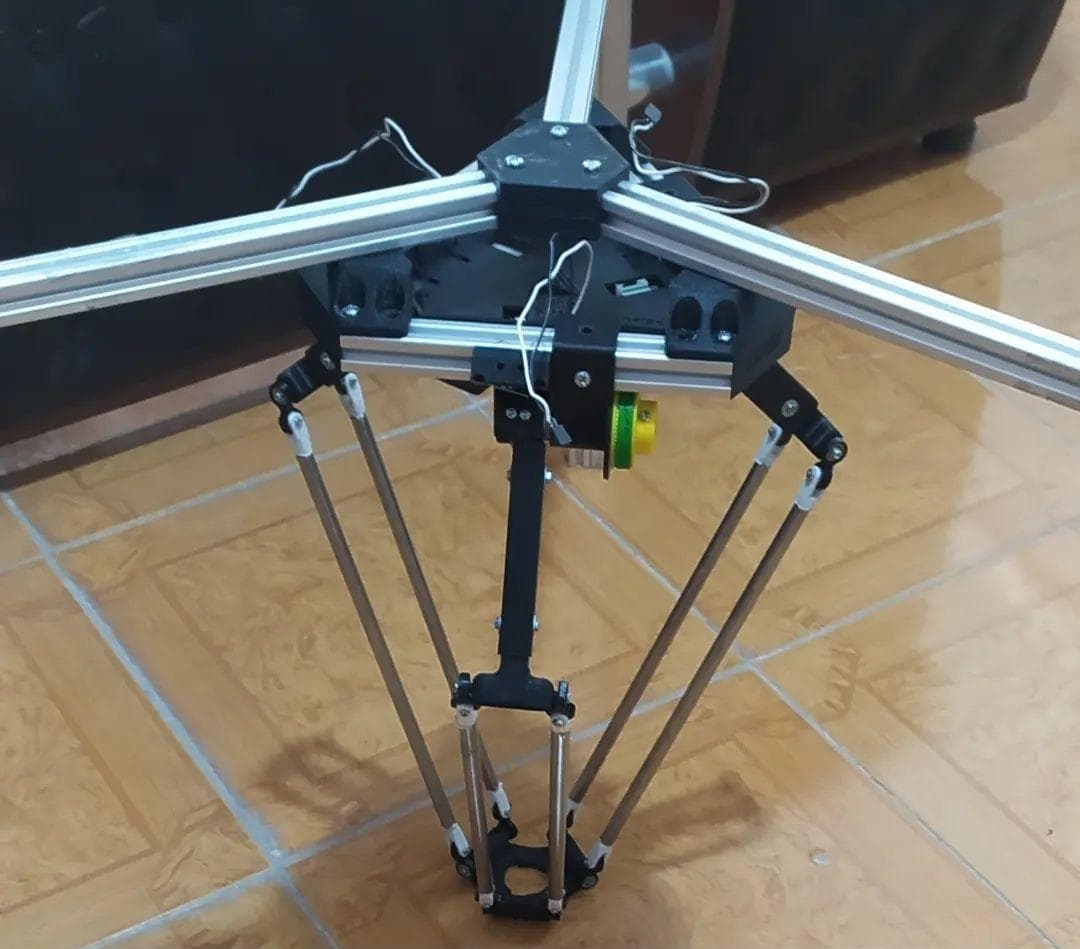
Many delta-robot applications use predefined part positions or mechanical fixtures. NELSco built a prototype that combines RGB-D depth data with deep learning to identify parts across a defined range of orientations and provide grasp targets to the robot.
Intel RealSense RGB-D data for 3D position estimation, with TensorFlow/Keras segmentation to extract candidate part boundaries.
Custom inverse kinematics converts the 3D target into motor commands, with a pneumatic end effector tailored to the tested product; new products require retraining and validation.
The Challenge
The challenge was to detect irregular parts in varied orientations, estimate suitable grasp boundaries and targets, and translate 3D target coordinates into motion commands within the prototype's test-cycle timing.
Our Approach
An Intel RealSense camera supplies RGB-D data for 3D position estimation. TensorFlow/Keras segmentation extracts candidate part boundaries, and a custom inverse-kinematics controller converts the selected target into motor commands. The pneumatic end effector was built for the tested product geometry; a new product requires new data, tuning, and validation.
The Result
The result was a prototype automation cell combining machine vision, deep learning, and robot control for parts in the tested orientation range. In suitable applications this approach can reduce reliance on alignment fixtures; final accuracy and throughput depend on validation with the target product and line speed.
Results
- Picking across tested part orientations with reduced reliance on alignment fixtures
- Reduces reliance on mechanical alignment fixtures
- Enables evaluation of vision-guided picking for parts in varied orientations
Have a similar project?
Get in touch with NELSco's engineering team to discuss your project requirements.